Praxis-1 is an Automation tool. Open-weight AI model that uses video pretraining to control robots across different hardware. Key features include Video-Based Learning, Cross-Embodiment Control, and Complex Task Handling. Best for software developers and engineers and scientists and researchers.
About Praxis-1
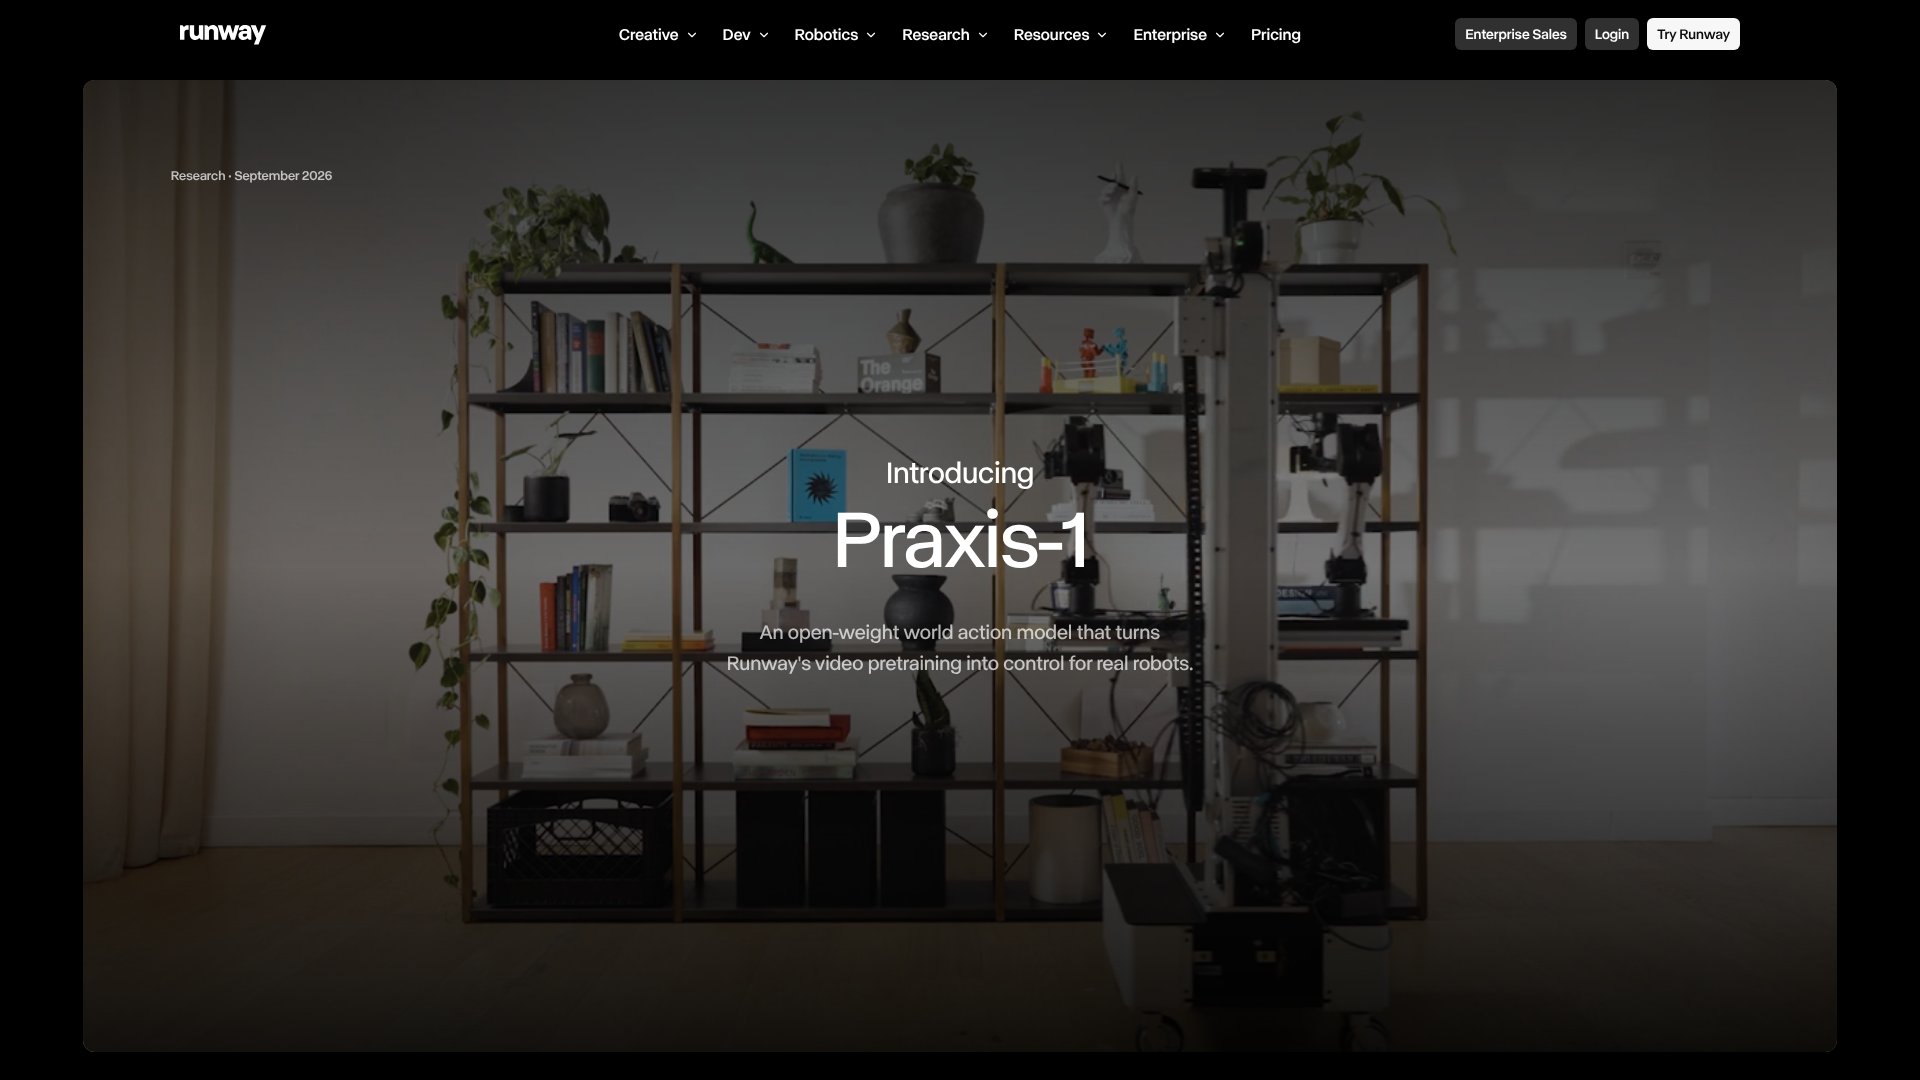
Praxis-1 is an open-weight world action model from Runway that turns large-scale video pretraining into real-world robot control. It works across different robot types and environments, learning from web video to reduce the need for costly robot demonstrations.
Key Features
Video-Based Learning.
Cross-Embodiment Control.
Complex Task Handling.
High Simulation Accuracy.
Open-Weight Release.
Environment Generalization.
Frequently Asked Questions
Praxis-1 is a world action model that controls real robots. It uses video pretraining to teach robots how to perform physical tasks across different environments and hardware types. Robotics developers and researchers use Praxis-1 to reduce the amount of expensive demonstration data needed for robot training.
Praxis-1 is currently being tested with early hardware partners including Noble Machines, Standard Bots, and Ultra. Runway plans to release the model publicly with open weights in the coming months, though no specific release date has been announced yet.
Praxis-1 learns from large-scale video pretraining, including web videos of everyday tasks and human demonstrations. This approach teaches the model about physics, object behavior, and task execution before fine-tuning on robot-specific data, reducing the need for costly teleoperated demonstrations.
Praxis-1 works across different robot types and environments without retraining, which is unusual for robot control models. It also learns primarily from video rather than robot demonstrations, and will be released as an open-weight model rather than a proprietary closed system.